Factory automation is a system that automates everything from product planning, design, and production preparation to the control, management, and operation of production. It is a Flexible Manufacturing System (FMS) — a batch production process that connects robot- and computer-based production equipment with communication and material-handling equipment, using computer control to simultaneously produce, assemble, inspect, and package products of varying sizes and types, with the goal of improving production automation, flexibility, and output.
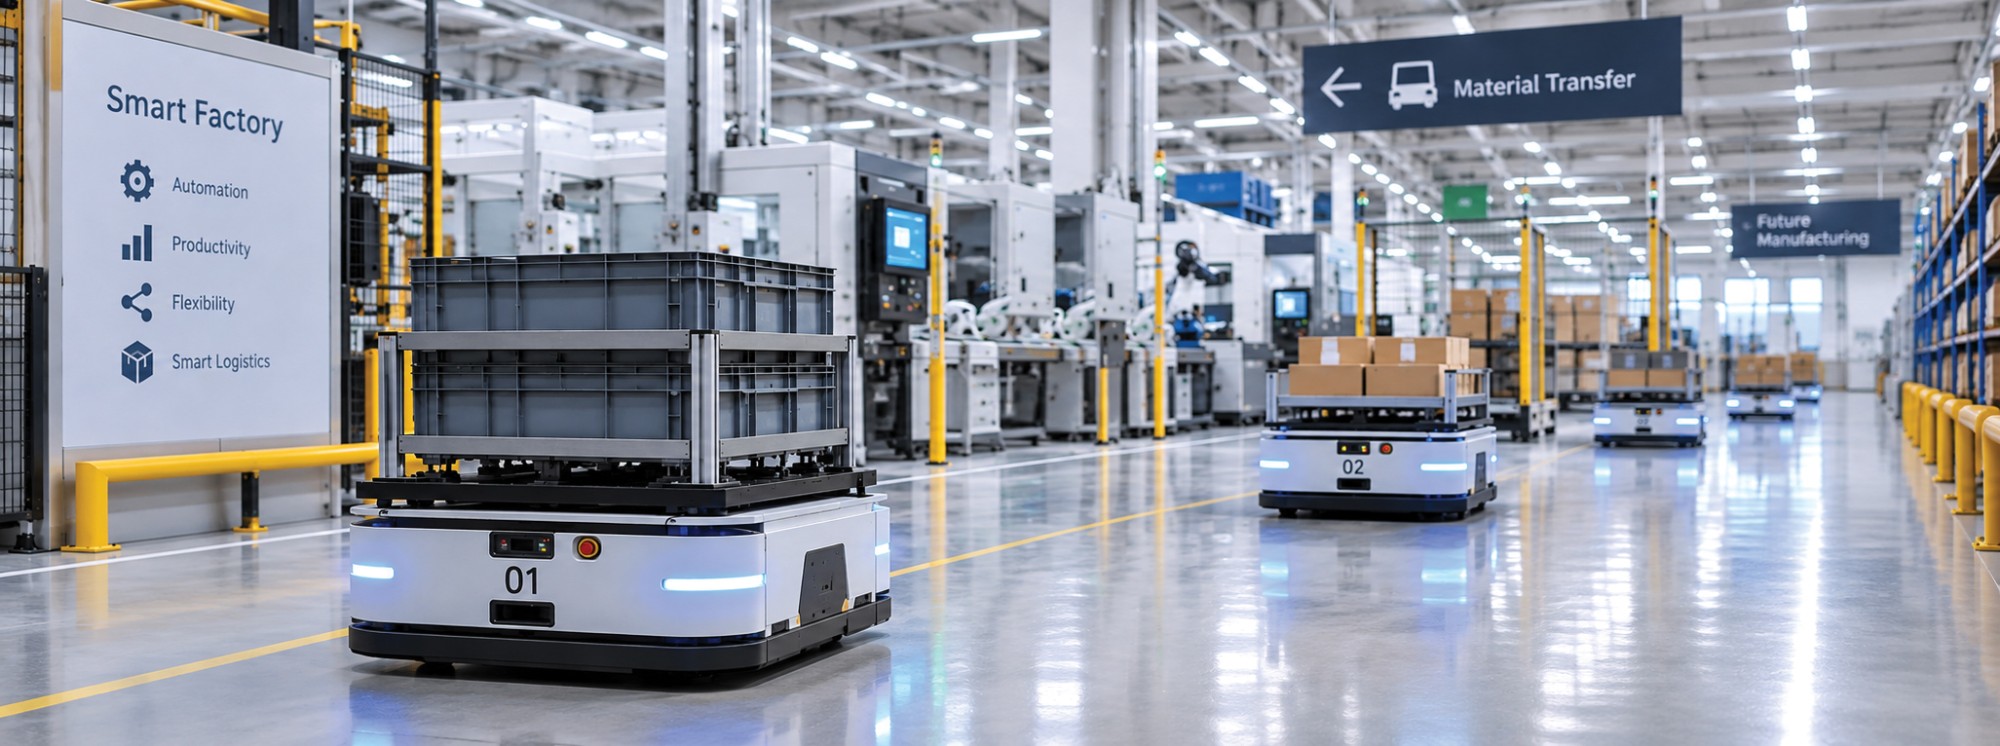
SLAM-based autonomous navigation moves materials between processes without operators. Existing routes and floor conditions are used as they are, enabling phased adoption without stopping the line.
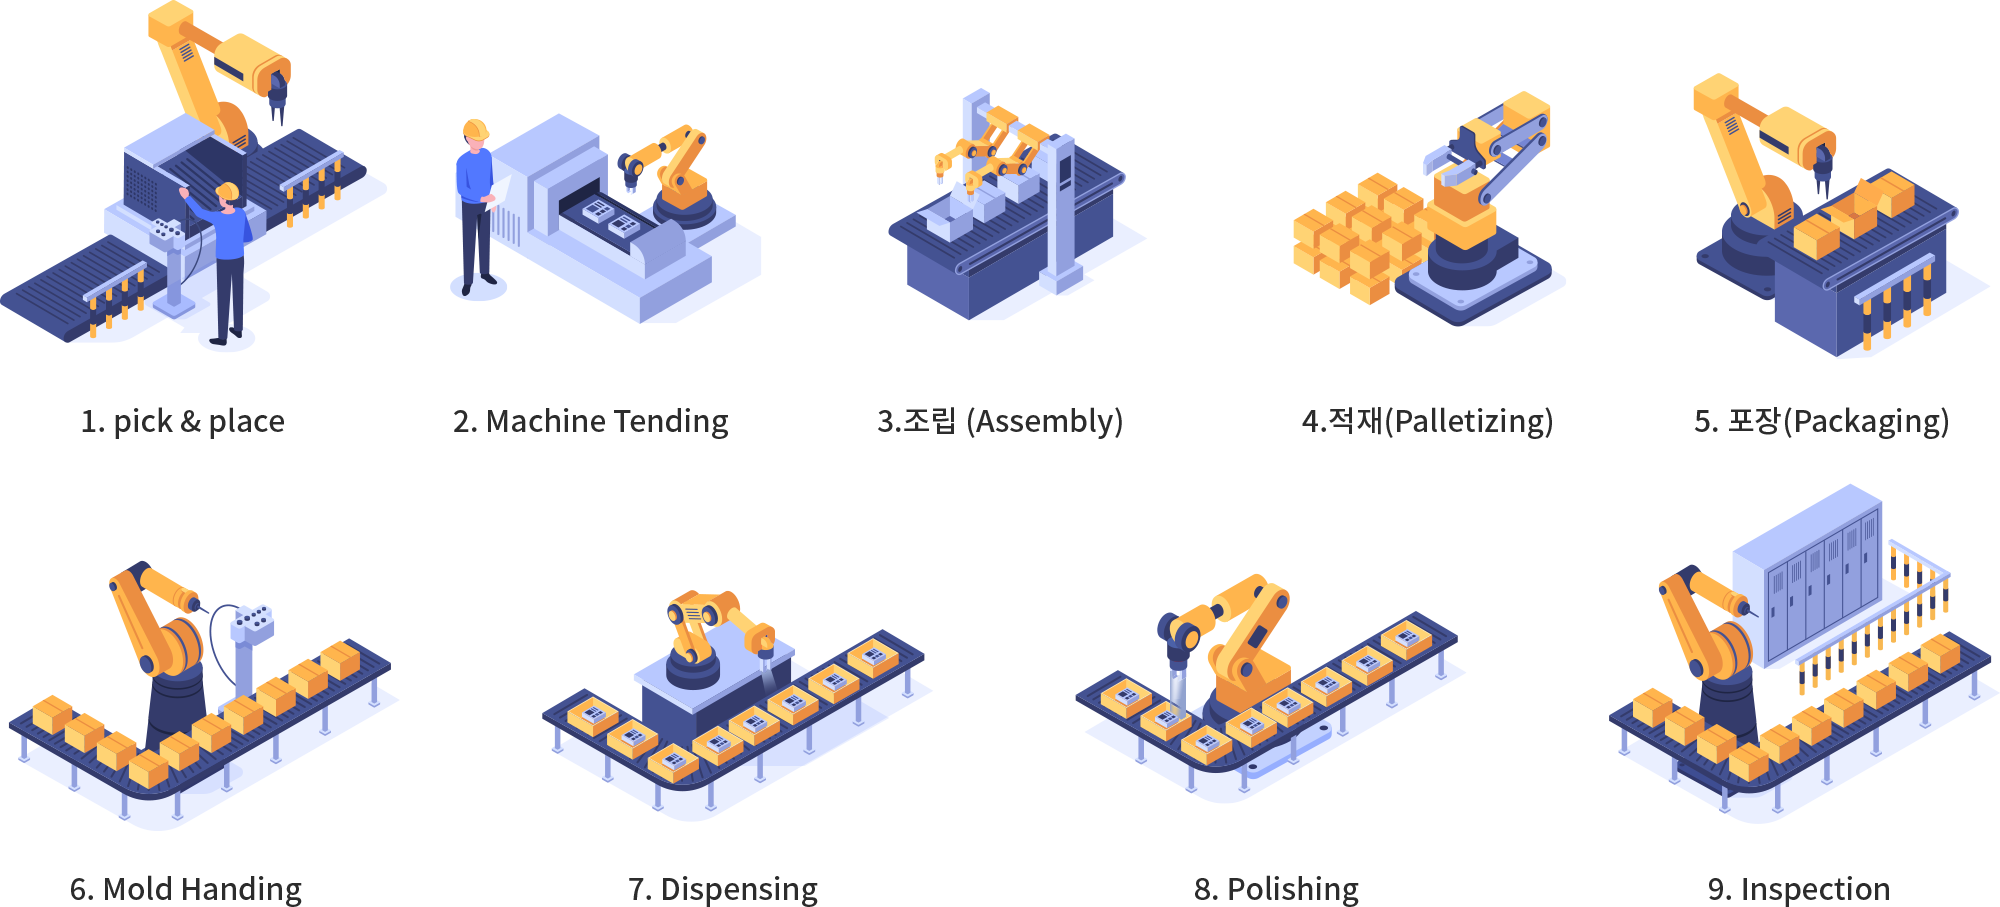
We build loading, transfer, assembly, and palletizing cells with articulated, collaborative, and delta robots, designing everything from grippers and jigs to safety fences.
We design and build process-specific jigs and transfer, assembly, and inspection equipment in-house. One team handles everything from mechanical design to PLC control and HMI.
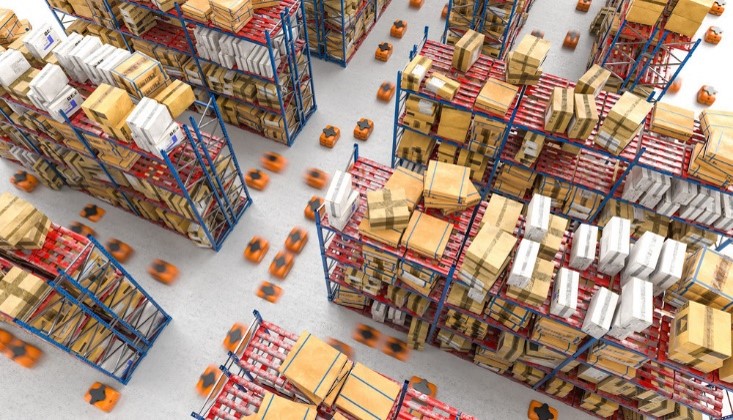
Automated storage, shuttles and stackers, and conveyor sorters are connected to WMS to automate inbound and outbound operations, improving inventory accuracy and storage density at the same time.
AI vision inspects every unit for appearance, dimension, and label defects, and automatically accumulates defect images and root-cause data for process improvement.
Scattered equipment data is brought onto a single screen to visualize utilization, downtime causes, and material flow in real time, integrated with MES and ERP.
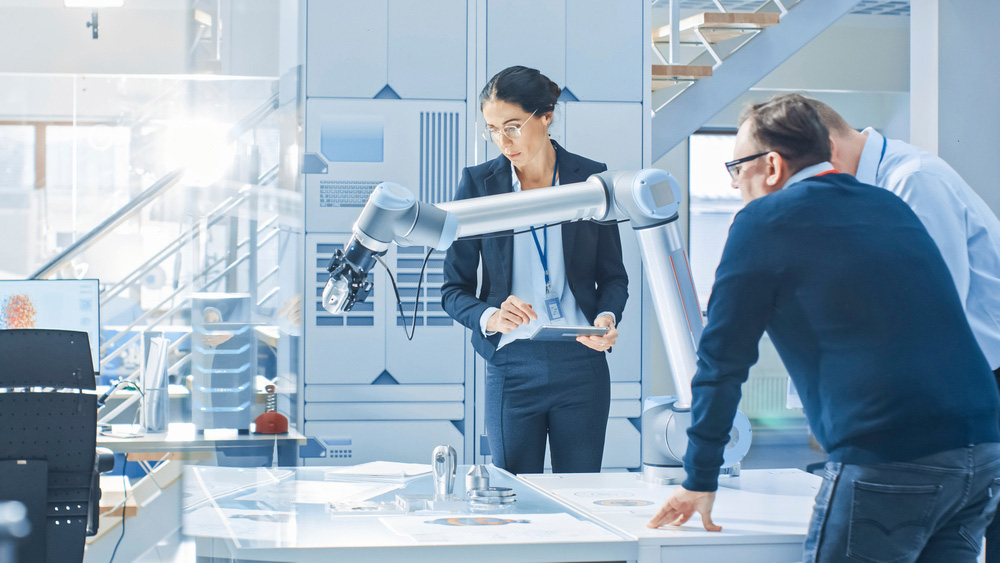
A collaborative robot, also known as a cobot, is a robot designed to work alongside a human operator in the same space. Rather than replacing the worker, a collaborative robot represents a human-robot partnership model that maximizes work efficiency and productivity by working together with people.
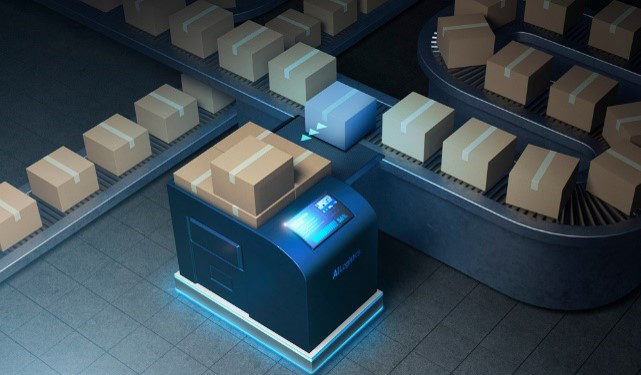
AGVs operate on a fixed path guided by wires, magnetic tape, or sensors.
These paths are predefined and require extensive installation, which can be costly and disrupt production.
AGVs carry only minimal onboard intelligence and can follow only simple programmed instructions.
They can detect obstacles but cannot navigate around them, so they stop until the obstacle is cleared.
Changing an AGV's fixed path incurs additional cost and downtime.
AMRs, by contrast, are equipped with intelligent navigation capabilities.
Using cameras, sensors, and laser scanners along with sophisticated software, they build maps and navigate autonomously.
Unlike AGVs, AMRs do not rely on a fixed path. They can detect obstacles, choose the optimal alternative route, and safely maneuver around them.
This keeps material flow uninterrupted and optimizes productivity.
The intelligent navigation of AMRs makes them the preferred choice when weighing AMRs against AGVs for dynamic environments.
 Blog
 YouTube
 Naver TV
 Naver Clip